Plenary Session: Ken Goldberg
Plenary Session
Tuesday, February 2, 2027, at Moscone West in San Francisco
Physical AI: Closing the Data Gap with 3D Physics Models and Good Old-Fashioned Engineering
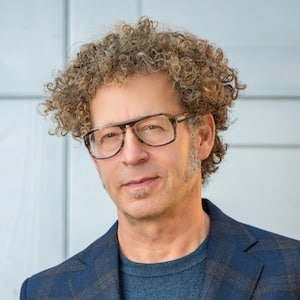
Ken Goldberg
William S. Floyd Distinguished Professor of Engineering, UC Berkeley
About the Talk
Physical AI—systems that perceive and act in the physical world—is advancing rapidly, and expectations are running ahead of results. The prevailing bet is that end-to-end models trained on massive datasets will do for robots and autonomous systems what large language models did for text. Ken Goldberg argues that this bet underestimates a structural obstacle, and that closing the gap will require a different approach to both data and system architecture.
The obstacle is data. Where language models had an internet containing roughly 100,000 years’ worth of human reading material, there is no comparable archive of physical interaction. Video carries limited and often misleading information about geometry, weight and material properties, and collecting data through human teleoperation does not scale. Goldberg will present new work from UC Berkeley’s AUTOLab on using vision-language models and agents to process images and video into detailed 3D physics models, iterating until simulation matches observed reality, generating training data at scale without additional robots or human demonstration.
He then turns to architecture, contrasting end-to-end learned systems with what he calls “Good Old-Fashioned Engineering”: modular designs in which learned components are integrated with proven algorithmic methods such as state estimation, outlier rejection and motion planning. Drawing on deployed systems, including package-sorting robots that have handled over 100 million packages, he will examine why modular designs are often more efficient and more debuggable under real-world constraints on power, latency and reliability.
Integrating these two cultures remains an open problem. Goldberg will close by asking whether AI coding agents, which generate inspectable and testable code rather than opaque policies, offer a path forward, and what the next generation of physical AI systems will demand of machine perception.
About Ken Goldberg
Ken Goldberg is William S. Floyd Distinguished Professor of Engineering at UC Berkeley, a member of the US National Academy of Engineering and an award-winning roboticist, filmmaker and artist. He has been interested in robots, rockets, redwoods and rebels since he was a kid. He’s skeptical about claims that humans are on the verge of being replaced by superintelligent machines but optimistic about the potential of technology to improve the human condition. Ken developed the first provably complete algorithm for part feeding and the first robot on the Internet. He was awarded the Presidential Faculty Fellowship and elected IEEE Fellow “for contributions to networked telerobotics and geometric algorithms for automation.”
Ken is also an artist whose work has been featured in 70 art exhibits worldwide including the Whitney Biennial. He founded UC Berkeley’s Art, Technology, and Culture public lecture series. Ken is co-founder and Chief Scientist at Ambi Robotics and on the Editorial Board of the journal Science Robotics. He served as Chair of the Industrial Engineering and Operations Research Department and co-founded the IEEE Transactions on Automation Science and Engineering. Short documentary films he co-wrote were selected for Sundance; one was nominated for an Emmy Award. He lives in the Bay Area and has two daughters with his wife and frequent creative collaborator, filmmaker, author, artist and Webby Awards founder Tiffany Shlain.
See you February 2-4, 2027 in San Francisco, California
-
-
Sponsors and Exhibitors
Interested in sponsoring or exhibiting?
The Embedded Vision Summit gives you unique access to the best qualified technology buyers you’ll ever meet.February 2-4, 2027
San Francisco -
Get in Touch
Want to contact us?
Use the small blue chat widget in the lower right-hand corner of your screen, or the form linked below.STAY CONNECTED
Follow us on X and LinkedIn.